
Sumo robotics is one of the most exciting ways to learn engineering, programming, and robot strategy. In a sumo...
Please note that our online shop will be temporarily closed due to relocation from Sep 14th to Oct 22nd , 2026. We apologize for any inconvenience and appreciate your patience during this transition.
We look forward to serving you again soon. Thank you for your continued support.
— Management
Latest posts
-
 Building a SPIKE Prime 3 Sumo Robot with SPSumoeyesread more
-
 Wall-Following Robot with LEGO SPIKE Prime 3read more
Building a Wall-Following Robot with LEGO SPIKE Prime 3 and the Mindsensors DIST-ToF Sensor
-
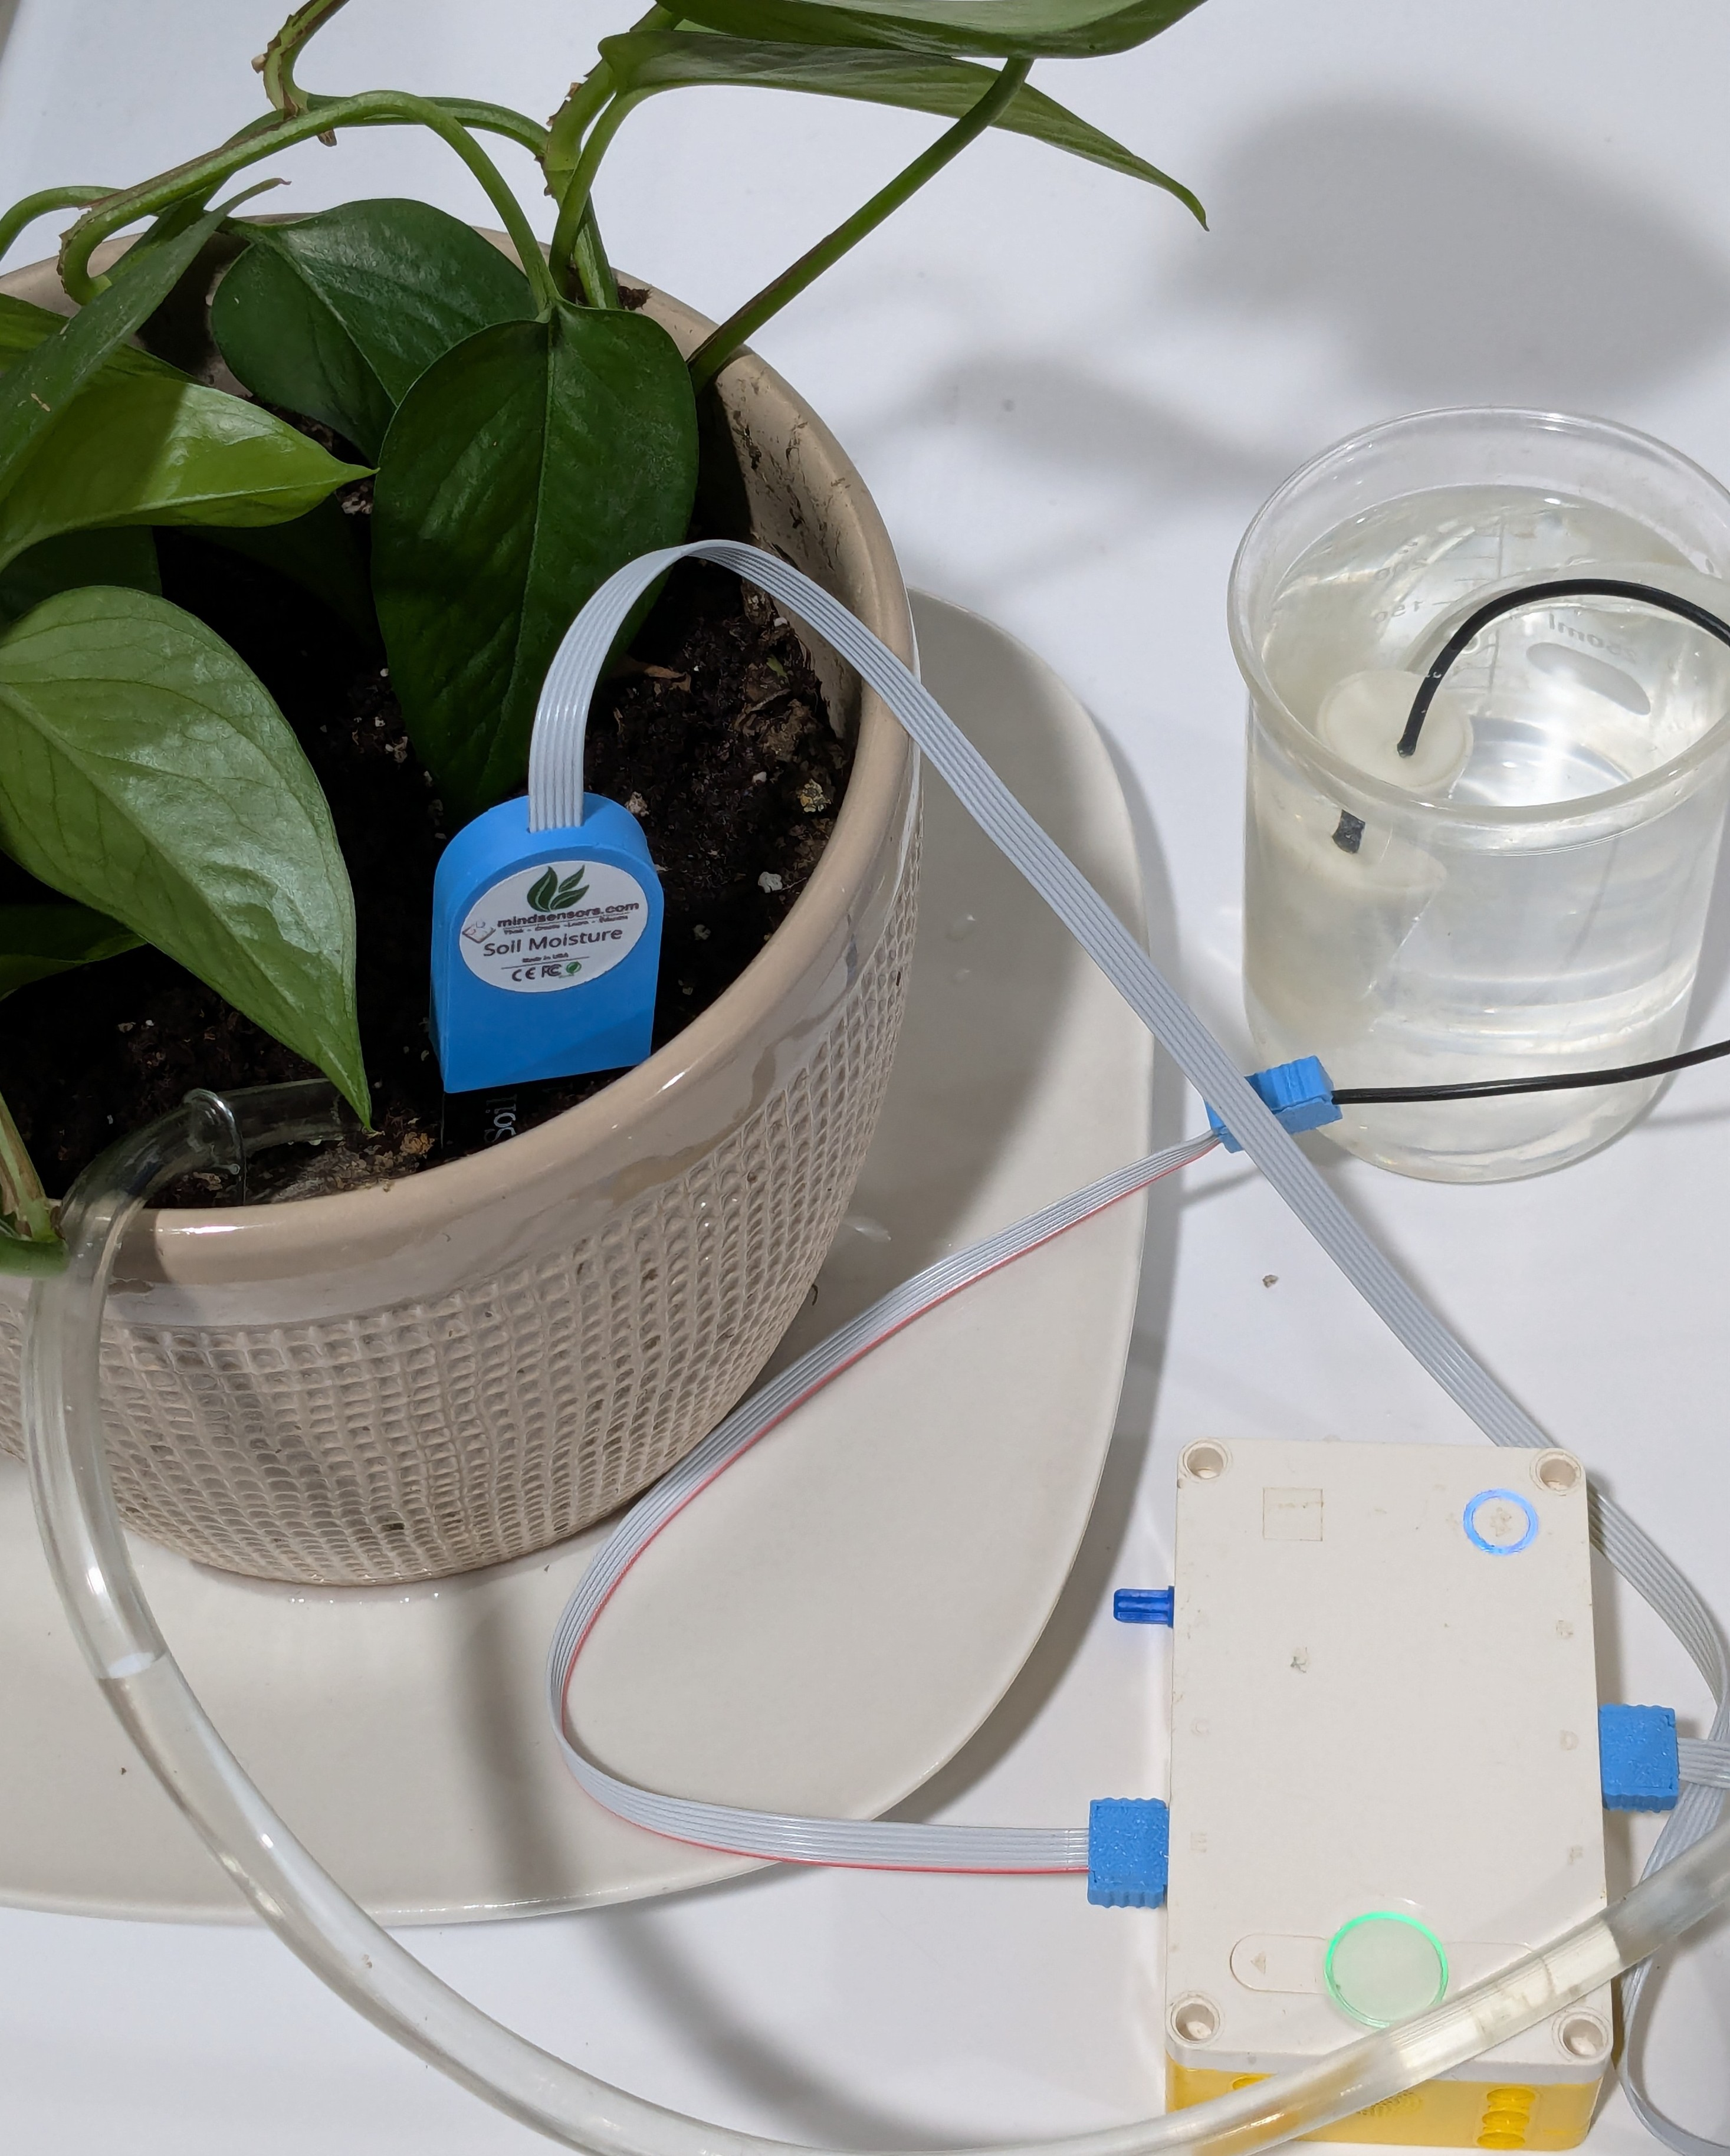 How to Measure Soil Moisture and Use It in Automatic Plant Watering Systemsread more
Keeping plants healthy isn’t just about giving them water — it’s about giving them the right amount at the right...
-
 USB Driver installation instructions for NXTCam-v5read more
USB Driver installation instructions for NXTCam-v5
-
 How to attach rechargeable battery to PiStormsread more
How to attach rechargeable battery to PiStorms
-
 Connect to Wi-Fi Directly from PiStorms!read more
Connect your Raspberry Pi to a Wi-Fi network directly from PiStorms!
-
 Image Recognition Robot with PiStorms and Pi Cameraread more
Image Recognition Robot with PiStorms and Pi Camera
-

-
 Rotary Inverted Pendulum with PF-XL Motor and GlideWheel-Mread more
Rotary Inverted Pendulum with PF-XL Motor and GlideWheel-M
-

Blog categories
Search in blog
Archived posts

Line Tracking Experiments with NXTCam
Below are the results of a few line tracking experiments.
The picture pairs below are screen dumps of NXTCamView.
In the pair:
First picture is "Image Capture" as taken in NXTCamView
Second picture is tracking window for that view.
The black lines in the following pictures are actually a NXT sensor cable. The red line is a plastic ribbon.
In line tracking mode, it is advisable to use non-reflective material.
Horizontal and Vertical black lines:


Horizontal red line and a vertical black line:


Vertical red line and a horizontal black line:


Two vertical black lines:


Posted in:
NXT & EV3
Related posts
-
 Line Following Robot with LightSensorArray or LineLeader
read more
-
 Attach Mulitple Sensors to a Single EV3 Port
EV3 Sensor Adapter with SPLIT-Nxread more
-
 Rainfall Alert
read more
-
 The Flame Sensor! A Grove Sensor Adapter project
read more
-
 Cheer With Me! A Grove Sensor Adapter project
read more
Leave a comment