
Sumo robotics is one of the most exciting ways to learn engineering, programming, and robot strategy. In a sumo...
Please note that our online shop will be temporarily closed due to relocation from Sep 14th to Oct 22nd , 2026. We apologize for any inconvenience and appreciate your patience during this transition.
We look forward to serving you again soon. Thank you for your continued support.
— Management
Latest posts
-
 Building a SPIKE Prime 3 Sumo Robot with SPSumoeyesread more
-
 Wall-Following Robot with LEGO SPIKE Prime 3read more
Building a Wall-Following Robot with LEGO SPIKE Prime 3 and the Mindsensors DIST-ToF Sensor
-
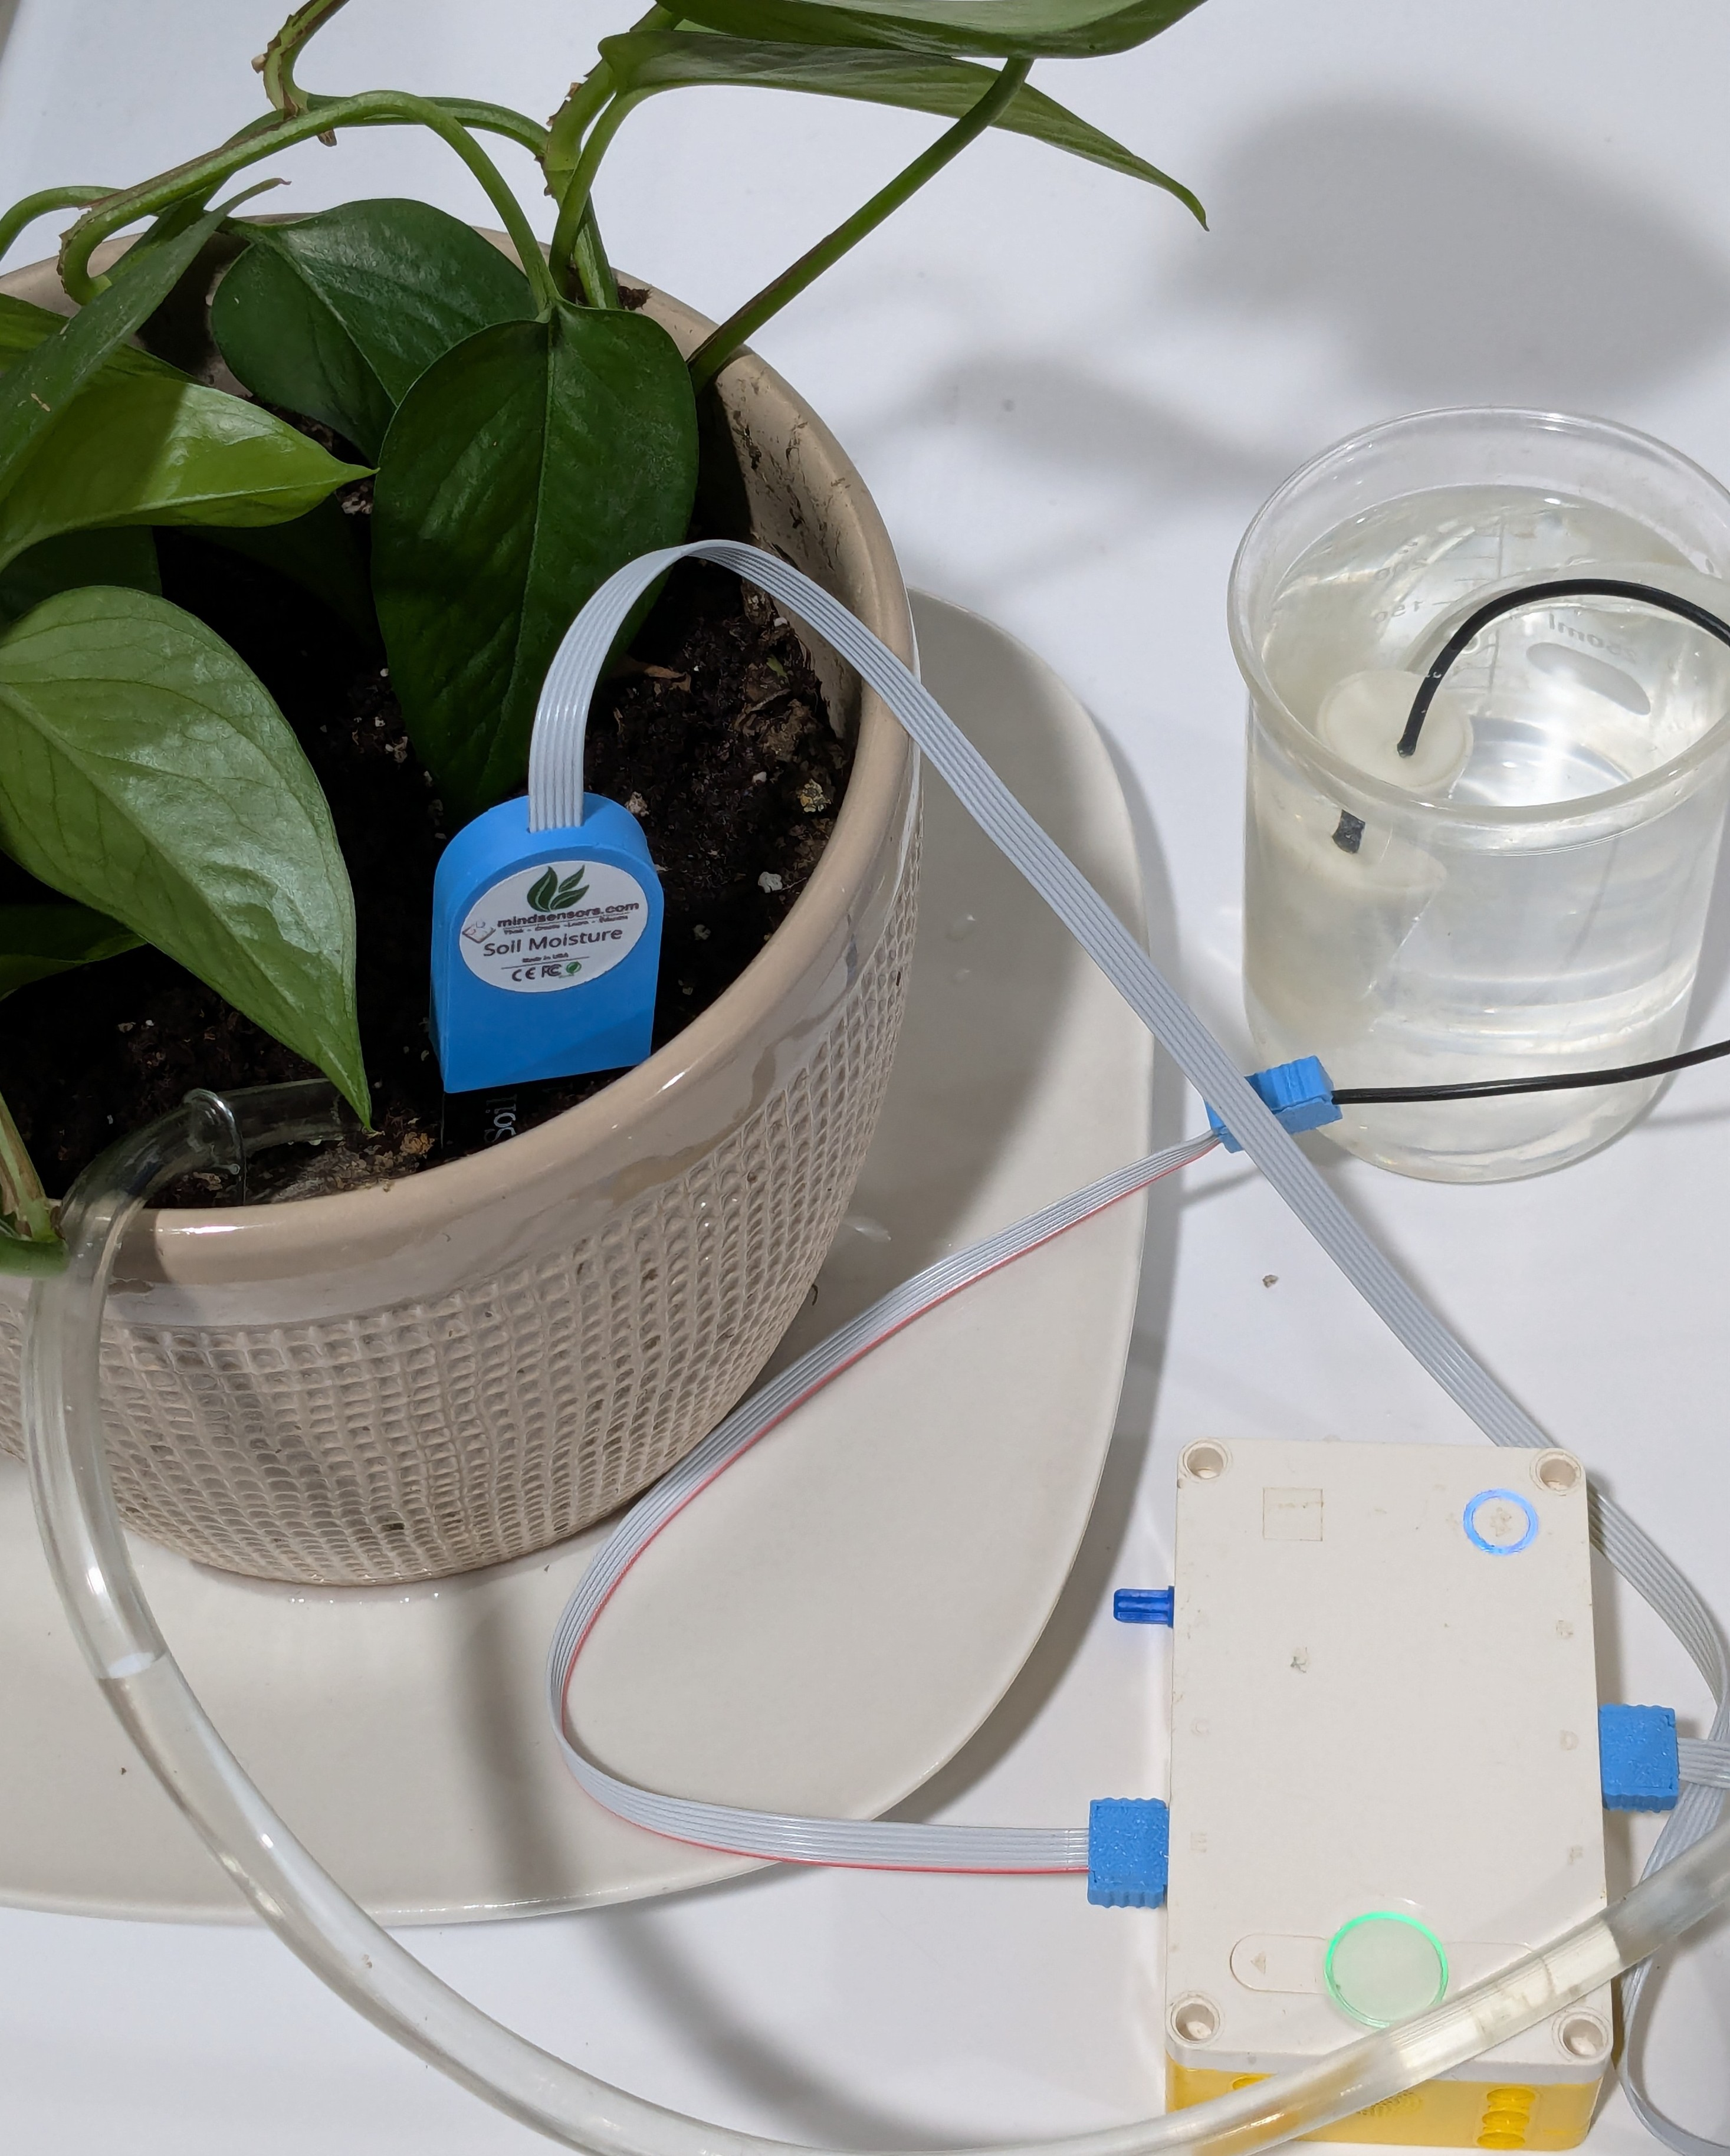 How to Measure Soil Moisture and Use It in Automatic Plant Watering Systemsread more
Keeping plants healthy isn’t just about giving them water — it’s about giving them the right amount at the right...
-
 USB Driver installation instructions for NXTCam-v5read more
USB Driver installation instructions for NXTCam-v5
-
 How to attach rechargeable battery to PiStormsread more
How to attach rechargeable battery to PiStorms
-
 Connect to Wi-Fi Directly from PiStorms!read more
Connect your Raspberry Pi to a Wi-Fi network directly from PiStorms!
-
 Image Recognition Robot with PiStorms and Pi Cameraread more
Image Recognition Robot with PiStorms and Pi Camera
-

-
 Rotary Inverted Pendulum with PF-XL Motor and GlideWheel-Mread more
Rotary Inverted Pendulum with PF-XL Motor and GlideWheel-M
-

Blog categories
Search in blog
Archived posts

Rotary Inverted Pendulum with PF-XL Motor and GlideWheel-M
PF-XL Motor Version
This rotary inverted pendulum (Furura pendulum) is built by using a "PF(power functions)-XL motor" and two angle sensors "GlideWheel-M".
We realized the swing-up control based on an energy method and the stabilized control based on LQ control.
Software for programming and control system analysis/synthesis is MATLAB/Simulink.
"Target for Use with LEGO MINDSTORMS NXT Hardware (Simulink Support Package for LEGO MINDSTORMS NXT Hardware)" is installed.
More information is as follows:
http://www.mathworks.com/help/simulink/lego-mindstorms-nxt.html
You can download some MATLAB/Simulink files (only stabilized control) and pictures about "PF-XL motor version" from the following URL.
http://www.maizuru-ct.ac.jp/control/kawata/lego_NXT_RoTH/matlab_pend_simple.zip
The folder "sfbk_crane_discrete" includes some files about the state feedback control of a crane.
The folder "sfbk_ip_discrete" includes some files about the state feedback control of an inverted pendulum.
We compared four kinds of LEGO motors (NXT, RCX, PF-XL and PF-M motors).
As a result, PF-XL motor is the best selection.
PF-M Motor Version
PF-M motor has a big deadzone, therefore, the response is not so good.
NXT Motor Version
NXT motor's backlash cannot be ignored, therefore, the response is not so good.
Related posts
-
 Line Following Robot with LightSensorArray or LineLeader
read more
-
 Attach Mulitple Sensors to a Single EV3 Port
EV3 Sensor Adapter with SPLIT-Nxread more
-
 Line Tracking Experiments with NXTCam
read more
-
 Vision for your PiStorms Robot using Pi Camera!
read more
-
 How to install OpenCV on Raspberry Pi and do Face Tracking
read more
Leave a comment